RLE-Based Model Predictive Control vs. Rule-Based Control for Energy Management in Multi-Architecture Electric Vehicles
DOI:
https://doi.org/10.18686/cest944Keywords:
model predictive control; electric vehicle energy management; supercapacitor hybrid; flywheel energy storage; ICE hybrid; regenerative braking; recursive least squares; process innovationAbstract
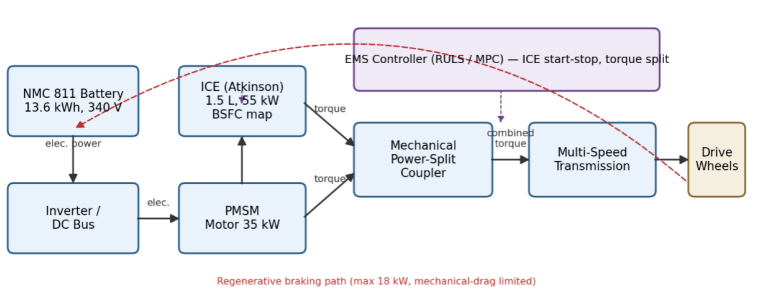
Energy management is a key factor in the range, safety and battery life of electrified vehicles. In this study, a Recursive Least Squares (RLS)-augmented Model Predictive Control (MPC) framework is designed and validated for real-time energy management of four different EV powertrain architectures: Battery Electric Vehicle (BEV), Battery-Supercapacitor Hybrid, Battery-Flywheel Hybrid, and Battery-ICE Hybrid. The architecture is built in MATLAB/Simulink R2022b; an RLS subsystem is used to adapt in real time the battery impedance parameters. Representative multi-regime drive cycles were used to evaluate all eight quantitative metrics of performance. RLS-MPC constantly outperformed the rule-based control for all the architectures. The velocity tracking RMSE was reduced by 10.4% (BEV), 14.9% (Supercapacitor), and 13.9% (ICE Hybrid). Energy use was lowered for BEV (−4.5%) and Supercapacitor (−3.7%) architectures, and auxiliary energy use was shown to be greater for hybrid architectures: +61.5% (Supercapacitor), +430.6% (Flywheel), and +73.7% (ICE Hybrid), with auxiliary storage pre-positioned in advance of an expected deceleration. The Supercapacitor-MPC configuration was able to operate with a near-zero net battery draw (+0.006 kWh) compared to the baseline. Flywheel-MPC had a final state-of-charge of 84.7% (when including conversion losses, this was not yet energy neutral, but close). The vectorized MATLAB implementation required less than 30 μs to compute one step; the projected embedded execution time on automotive microcontroller hardware is estimated to be between 20–40 ms, consistent with the 100 ms sampling budget. RLS-MPC has great promise for future use with next-generation electrified powertrains, and future work will focus on embeddability.
References
1. Aich W, Hajlaoui K, Alizadeh A, et al. Novel hybrid ANN with birds of prey-based algorithm and multi-objective flow direction optimization (MOFDO) for intelligent design of liquid cooling channels in electric vehicle battery thermal management. International Journal of Thermal Sciences. 2026; 225: 110789. doi: 10.1016/j.ijthermalsci.2026.110789
2. Rajamoorthy R, Arunachalam G, Kasinathan P, et al. A novel intelligent transport system charging scheduling for electric vehicles using Grey Wolf Optimizer and Sail Fish Optimization algorithms. Energy Sources, Part A: Recovery, Utilization, and Environmental Effects. 2022; 44(2): 3555–3575. doi: 10.1080/15567036.2022.2067268
3. Sharmila B, Srinivasan K, Devasena D, et al. Modelling and performance analysis of electric vehicle. International Journal of Ambient Energy. 2022; 43(1): 5034–5040. doi: 10.1080/01430750.2021.1932587
4. Mousavi G SM, Faraji F, Majazi A, et al. A comprehensive review of flywheel energy storage system technology. Renewable and Sustainable Energy Reviews. 2017; 67: 477–490. doi: 10.1016/j.rser.2016.09.060
5. Guzzella L, Sciarretta A. Vehicle Propulsion Systems: Introduction to Modeling and Optimization, 3rd ed. Springer; 2013.
6. Kim N, Cha S, Peng H. Optimal control of hybrid electric vehicles based on Pontryagin's minimum principle. IEEE Transactions on Control Systems Technology. 2011; 19(5): 1279–1287. doi: 10.1109/TCST.2010.2061232
7. Patil LN, Bhosale DG, Patil YM, et al. Investigation on different parameters associated with purchase of electric vehicle in India. Case Studies on Transport Policy. 2024; 15: 101152.
8. Serrao L, Onori S, Rizzoni G. ECMS as a realization of Pontryagin's minimum principle for HEV control. In: Proceedings of the 2009 American Control Conference; 10–12 June 2009; St. Louis, MO, USA. pp. 3964–3969.
9. Malikopoulos AA. Supervisory power management control algorithms for hybrid electric vehicles: A survey. IEEE Transactions on Intelligent Transportation Systems. 2014; 15(5): 1869–1885.
10. Bemporad A, Morari M, Dua V, et al. The explicit linear quadratic regulator for constrained systems. Automatica. 2002; 38(1): 3–20.
11. Borhan H, Vahidi A, Phillips AM, et al. MPC-based energy management of a power-split hybrid electric vehicle. IEEE Transactions on Control Systems Technology. 2011; 20(3): 593–603.
12. Zhang S, Xiong R, Sun F. A novel learning-based model predictive control strategy for plug-in hybrid electric vehicle. IEEE Transactions on Transportation Electrification. 2022; 8(1): 23–35.
13. Jia Y, Jibrin R, Itoh Y, et al. Energy-optimal adaptive cruise control for electric vehicles in both time and space domain based on model predictive control. IFAC-PapersOnLine. 2019; 52(5): 13–20.
14. Gros S, Zanon M. Data-driven economic NMPC using reinforcement learning. IEEE Transactions on Automatic Control. 2019; 65(2): 636–648.
15. Flessner D, Chen J, Xiong G. Reinforcement Learning-Based Event-Triggered Active-Battery-Cell-Balancing Control for Electric Vehicle Range Extension. Electronics. 2024; 13(5): 990.
16. Chen J, Behal A, Li C. Active battery cell balancing by real time model predictive control for extending electric vehicle driving range. IEEE Transactions on Automation Science and Engineering. 2023; 21(3): 4003–4015. doi: 10.1109/TASE.2023.3291679
17. Park S, Kwon S, Han K. RL-MPC Framework for Data-driven Energy Management in Mild Hybrid Electric Vehicles. IFAC-PapersOnLine. 2025; 59(3): 85–90.
18. Gan J, Li S, Lin X, et al. Multi-agent deep reinforcement learning-based multi-objective cooperative control strategy for hybrid electric vehicles. IEEE Transactions on Vehicular Technology. 2024; 73(8): 11123–11135.
19. Park S, Nguyen DG, Park J, et al. Deep neural network NMPC for computationally tractable optimal power management of hybrid electric vehicles. In: Proceedings of the 2024 American Control Conference; 10–12 July 2024; Toronto, ON, Canada. pp. 1640–1645.
20. Chen J, Meng X, Li Z. Reinforcement learning-based event-triggered model predictive control for autonomous vehicle path following. In: Proceedings of the 2022 American Control Conference; 8–10 June 2022; Atlanta, GA, USA
21. Rasheed MB, Llamazares Á, Gutiérrez-Moreno R, et al. Multi-Interest Dual-Adaptive Unscented Kalman Filter with Online Parameter Optimization for Nonlinear Battery Modeling. Journal of Energy Storage. 2026; 141(Part B): 118879.
22. Babazadeh M, Marco J, Niri MF. Augmented real-time lumped-parameter model for enhanced reliability in battery management systems. Journal of Energy Storage. 2025; 132(Part C): 117717.
23. Hu X, Li S, Peng H. A comparative study of equivalent circuit models for Li-ion batteries. Journal of Power Sources. 2012; 198: 359–367.
24. Mei P, Karimi HR, Huang C, et al. Remaining driving range prediction for electric vehicles: Key challenges and outlook. IET Control Theory and Applications. 2023; 17: 1875–1893. doi: 10.1049/cth2.12486
25. Karami M, Shahsavari S, Immonen E, et al. An Extension of the Kinetic Battery Model for Optimal Control Applications. IEEE Transactions on Industrial Electronics. 2023; 70(8): 234–245.
26. Dubarry M, Vuillaume N, Liaw BY. Origins and accommodation of cell variations in li-ion battery pack modeling. International Journal of Energy Research. 2010; 34(2): 216–231.
Downloads
Published
How to Cite
Issue
Section
License
Copyright (c) 2026 Digvijay Kanase, Arun Thorat, Pravin Mane, Prateek D. Malwe, Pramod Magade, Choon Kit Chan, Subhav Singh, Deekshant Varshney

This work is licensed under a Creative Commons Attribution 4.0 International License.